Seonghu Jeon.
I explore intelligence, aiming to connect agentic robotics, 3D/4D world modeling, and human-robot interaction. My work so far spans multi-view generation, geometric foundation models, and visuomotor policy learning.
News & notes
-
-
Education
Moving to the integrated M.S./Ph.D. program at KAIST, starting Spring 2027.
KAIST CVLAB, advised by Prof. Seungryong Kim. M.S. since March 2026.
- Paper
-
Paper
GAM was accepted to 3DWM @ ECCV 2026.
- Honor
-
Career
Joined MAUM AI's WoRV Division, Future Intelligence Lab as a research intern for Robotics Foundation Model development.
Research Intern, 2026.07 – Present.
-
Education
Joined KAIST CVLAB as an M.S. student under Prof. Seungryong Kim.
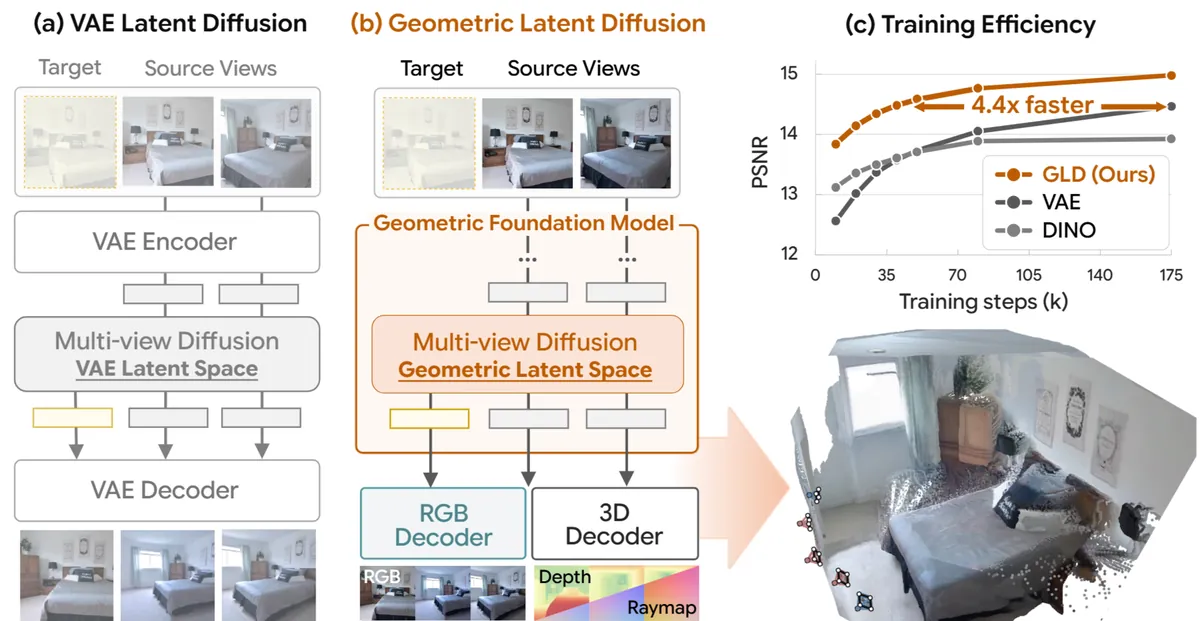
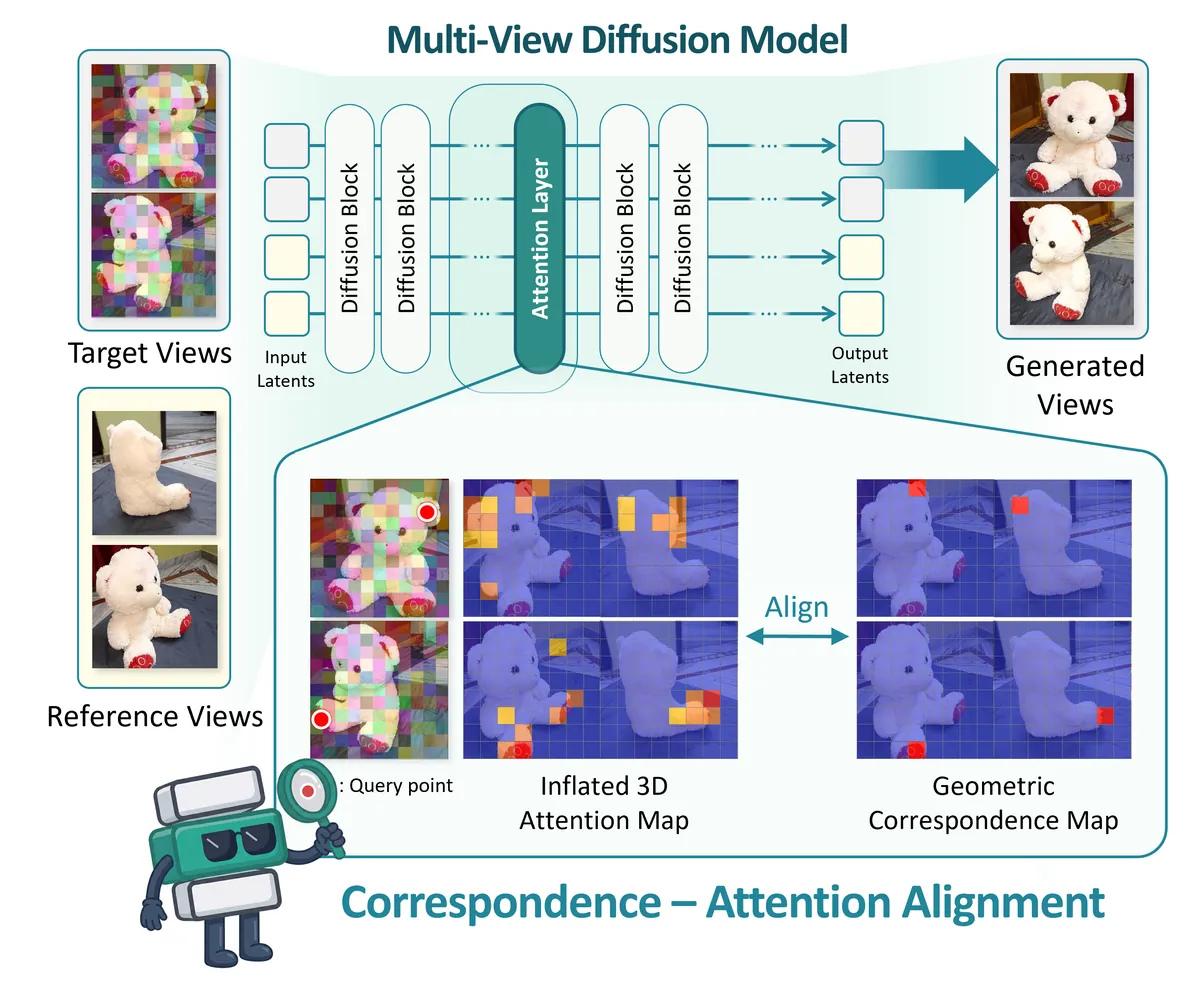
Multi-view diffusion, geometric foundation models, 4D scene generation.
- Paper
-
Education
Graduated from Korea University, B.S. in Computer Science & Engineering, with Great Honors.
Great Honors, GPA 4.46 / 4.50.
-
Education
-
-
Paper
ReMoTE was accepted to ITC-CSCC 2025 as an oral presentation.
ReMoTE: A Benchmark for Object Motion Transfer. First author.
-
Honor
Won 2nd Prize at the IEIE Undergraduate AI Paper Competition (AISP 2025).
Revisiting Flow-Conditioned Motion Transfer via Pseudo-Flow and Consecutive Local Attention
-
Paper
-
-
Honor
Received the National Science and Technology Scholarship from KOSAF.
-
Career
Moved to KAIST CVLAB with my supervisor, continuing as an undergraduate research intern.
-
Community
Started as DevRel Lead of GDGoC KU, Google Developer Groups on Campus at Korea University.
-
Honor
Received the merit-based Sangah Scholarship.
-
Honor
Received the merit-based Woonhae Scholarship.
-
Community
Started as President of AIKU, the Korea University AI Society.
-
Honor
-
-
Career
Joined CVLAB at Korea University as an undergraduate research intern under Prof. Seungryong Kim.
-
Honor
Won 1st Prize at the Korea-Yonsei University Datathon.
-
Honor
Won the Grand Prize at InThon, Korea University College of Informatics.
-
Career
Featured research
All publications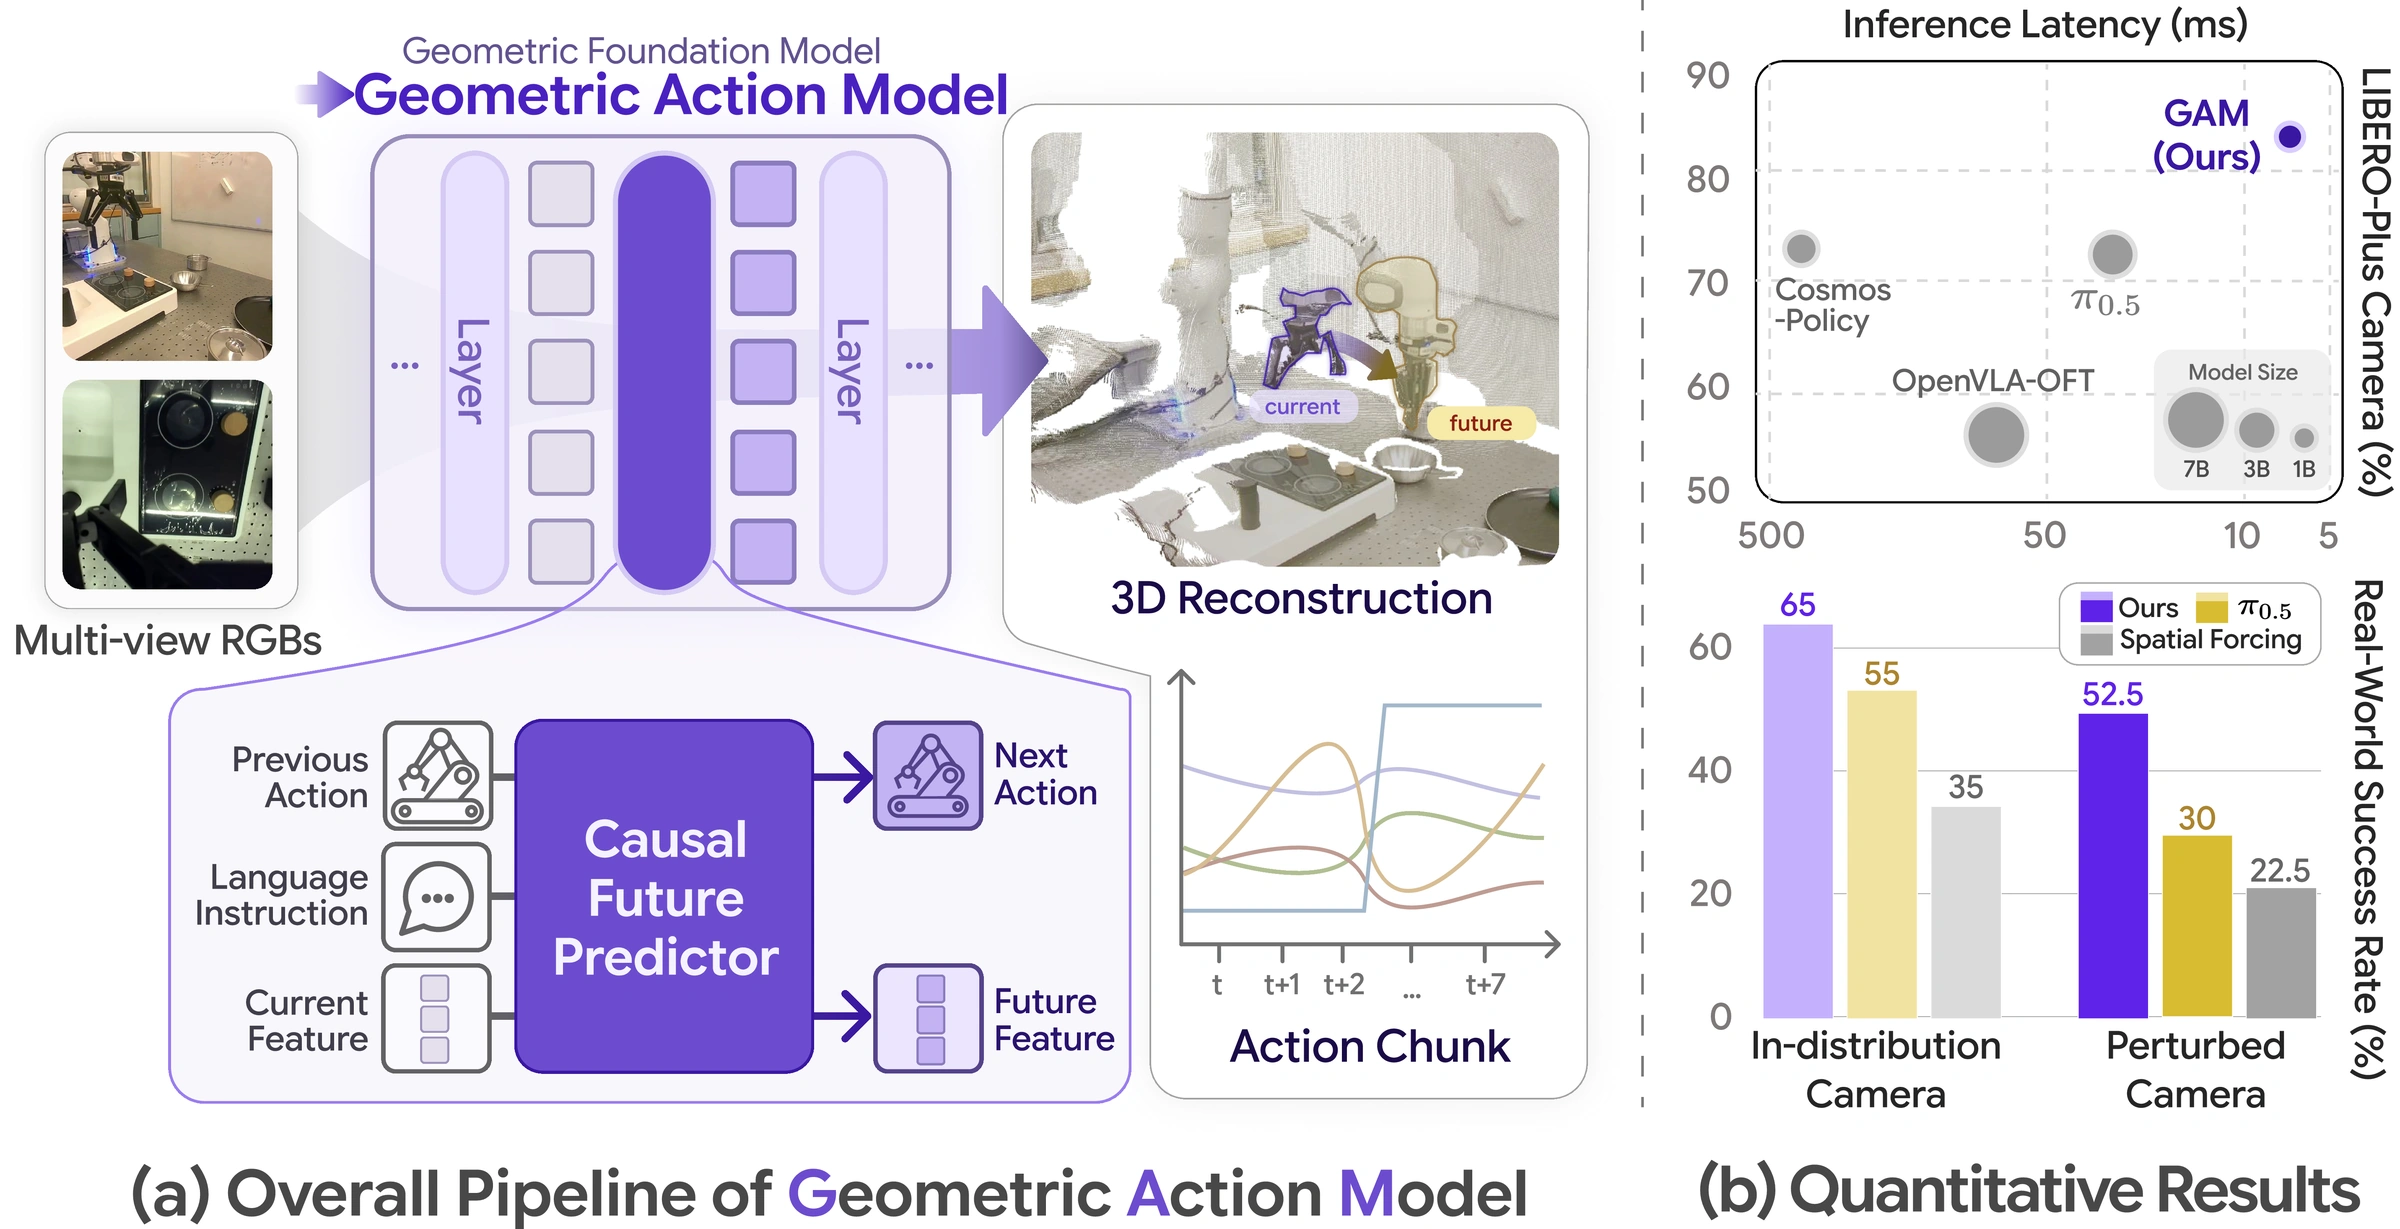
Focus
Agentic Robotics
Prefrontal cortex: planning what to do and in what order.
Human-Robot Interaction
Language areas: communicating with people.
3D/4D World Modeling
Cerebellum: geometric understanding and world modeling, for predicting the future and precise manipulation.
Experience
-
2026.07 – Present
Research Intern
MAUM AI, WoRV Division, Future Intelligence Lab
- Participating in Robotics Foundation Model development.
-
2026.03 – Present
Integrated M.S./Ph.D. Student
KAIST CVLAB
- Advised by Prof. Seungryong Kim.
- M.S. from March 2026, integrated M.S./Ph.D. program from Spring 2027.
- Multi-view diffusion, geometric foundation models, 4D scene generation.
-
2023.12 – 2026.02
Research Intern
CVLAB, Korea University → KAIST
- Researched generative 3D/4D vision, multi-view diffusion, flow matching, and geometric foundation models.
- Built evaluation benchmarks and geometry-aware action models for motion transfer, visuomotor control, and embodied scene understanding.
- Transferred to KAIST with the supervisor in Aug 2024.
-
2022 – 2026
B.S., Computer Science & Engineering
Korea University
- Graduated with Great Honors (4.46 / 4.50).
- Coursework in vision, graphics, and deep learning.